Quadruped Robot Motion Generation and Robot Control Between Sampling Points
9th Study Session
Quadruped Robot Motion Generation and Robot Control Between Sampling Points
Overview
The 9th Physical AI Study Group was held on August 21. In the first presentation, Kota Tsuruhara of Tokyo University of Agriculture and Technology introduced advances in motion-generation methods for quadruped robots and the KUPAC Quadruped Robot Project. In the second presentation, Fumiya Matsuzaki of Kyushu University introduced Lifted NMPC as a control method that accounts for behavior between sampling points.
Timetable
Registration Starts
16:30-16:45
Opening
16:45-16:50
Presentation 1: Quadruped Robot Motion Generation and the KUPAC Quadruped Robot Project
16:50-17:30 (Kota Tsuruhara, first-year master's student, Tokyo University of Agriculture and Technology)
Presentation 2: Robot Control That Considers Intervals Between Sample Points
17:30-18:10 (Fumiya Matsuzaki, third-year doctoral student, Graduate School of Mathematics for Innovation, Kyushu University)
Closing
18:10-18:15
Networking
18:15-19:30
Gallery
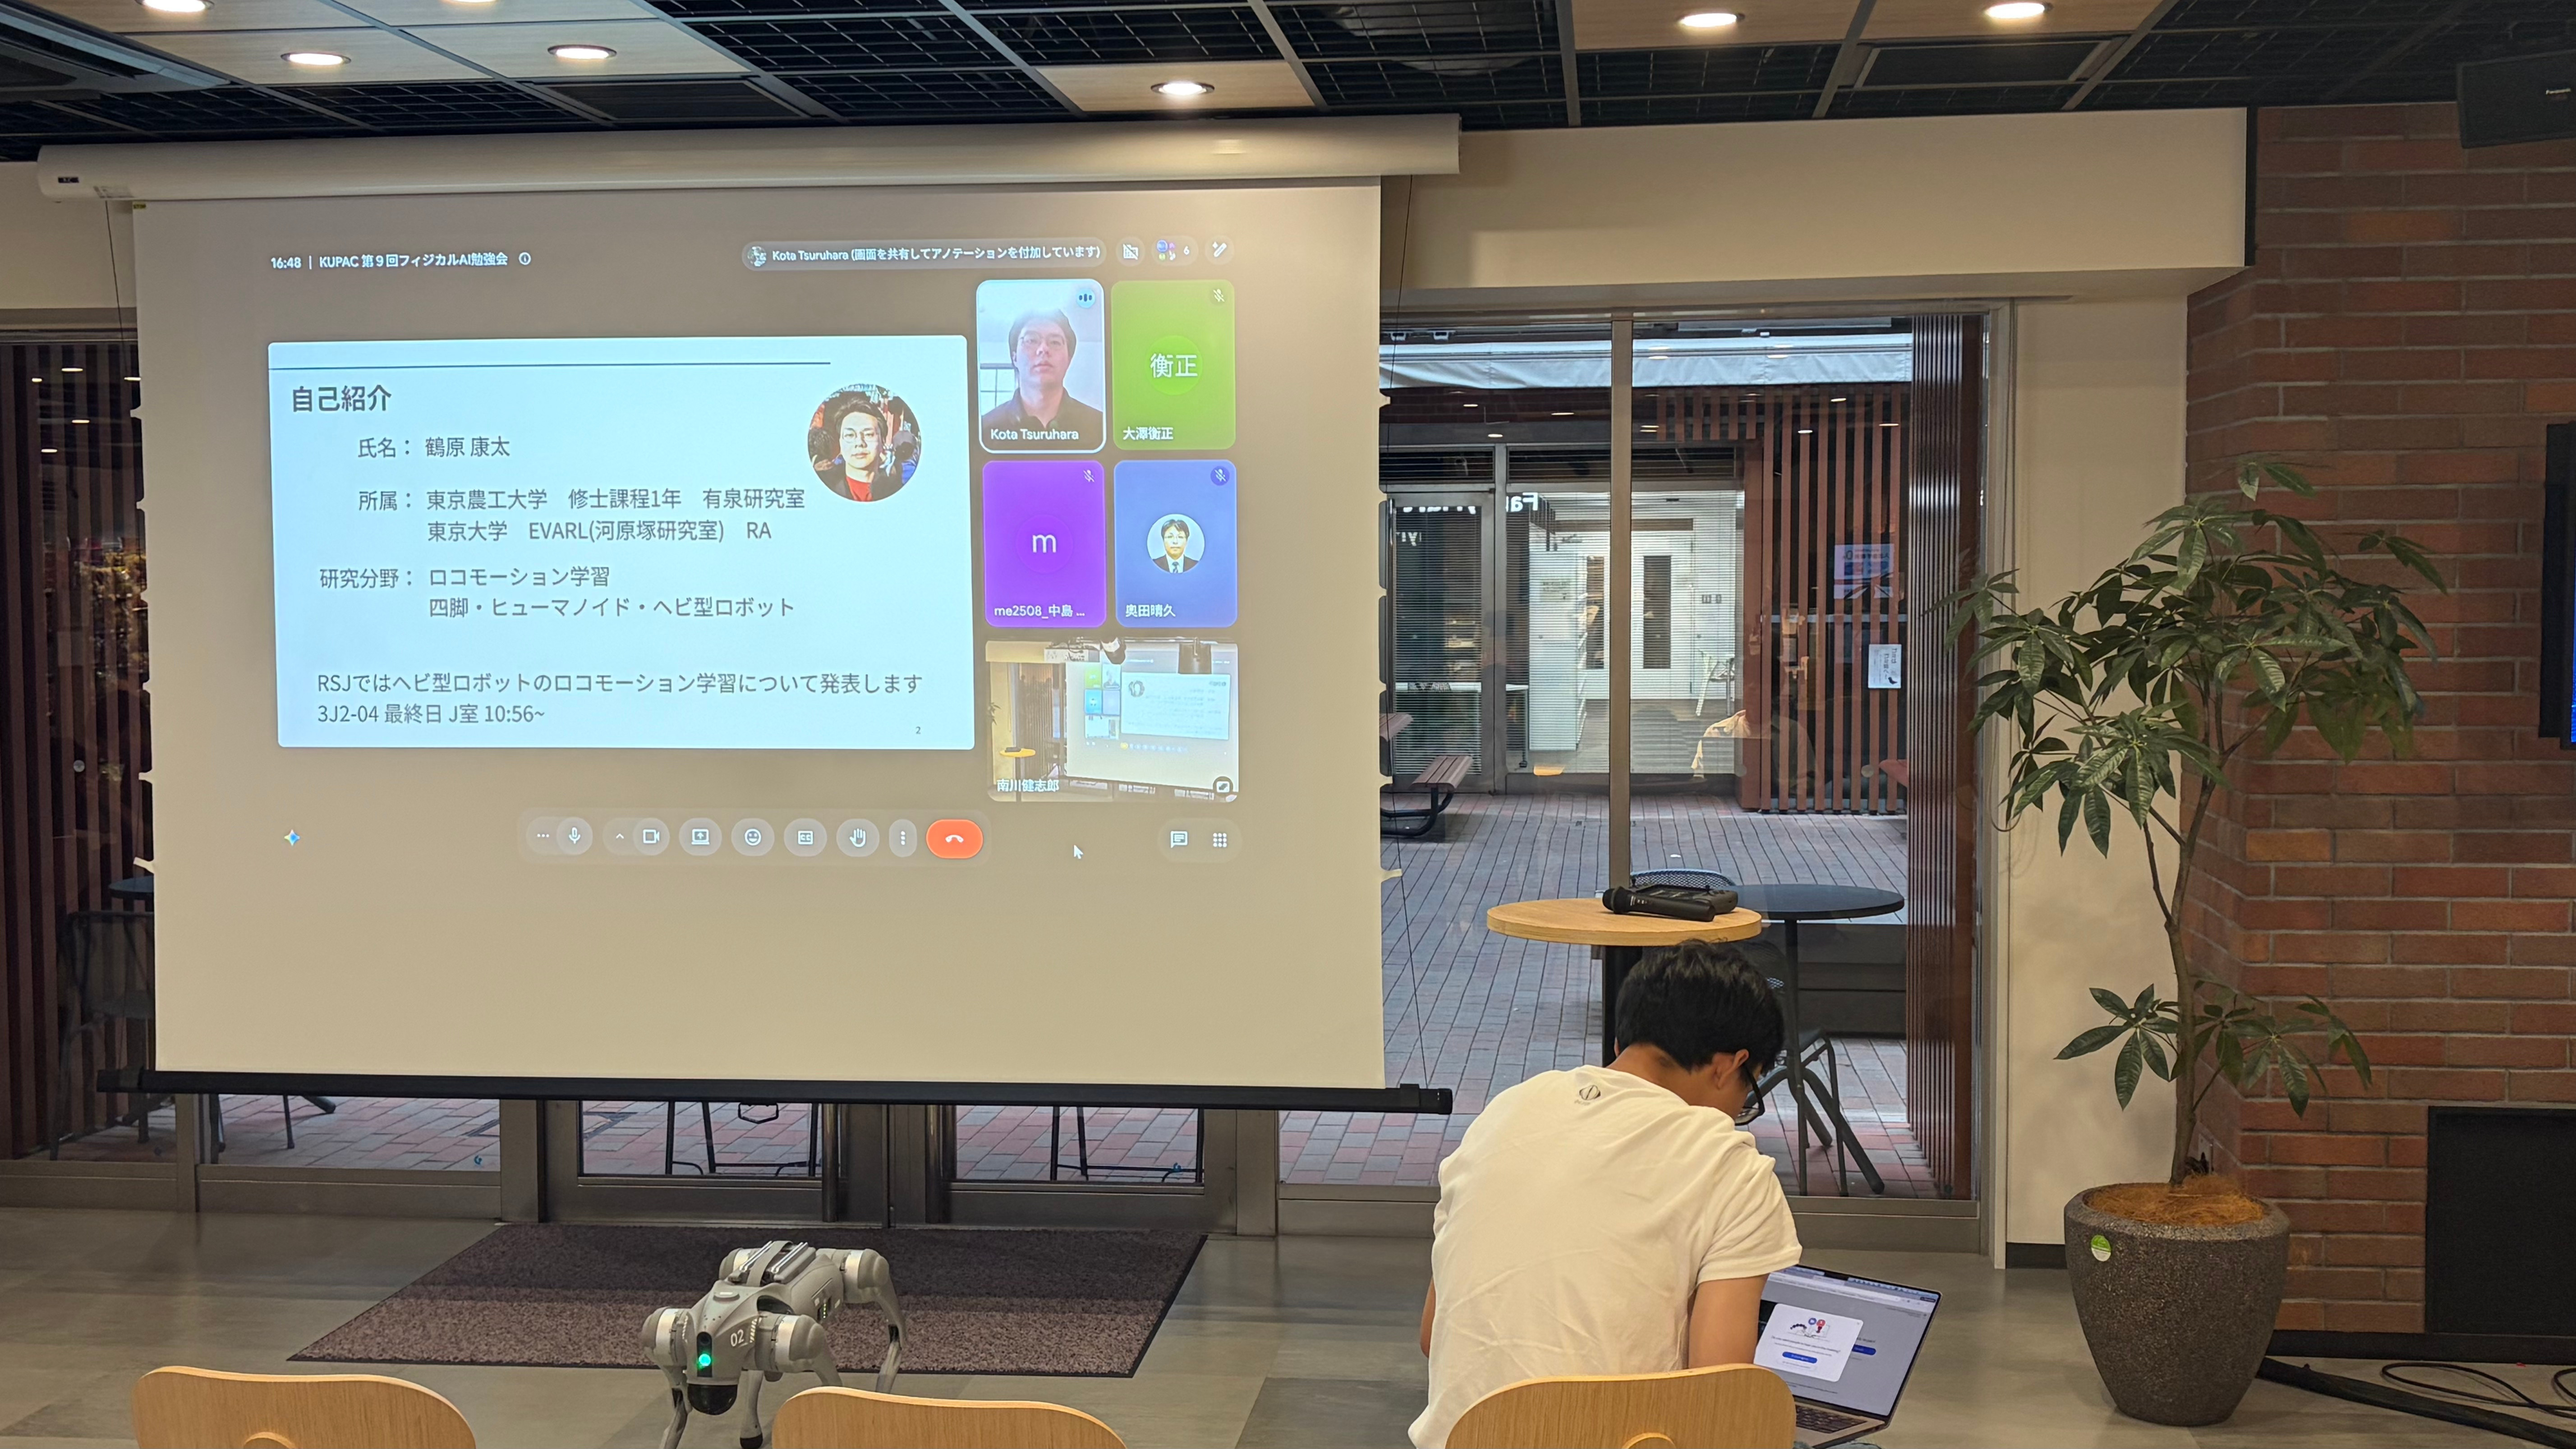
Presentation Scene (1)
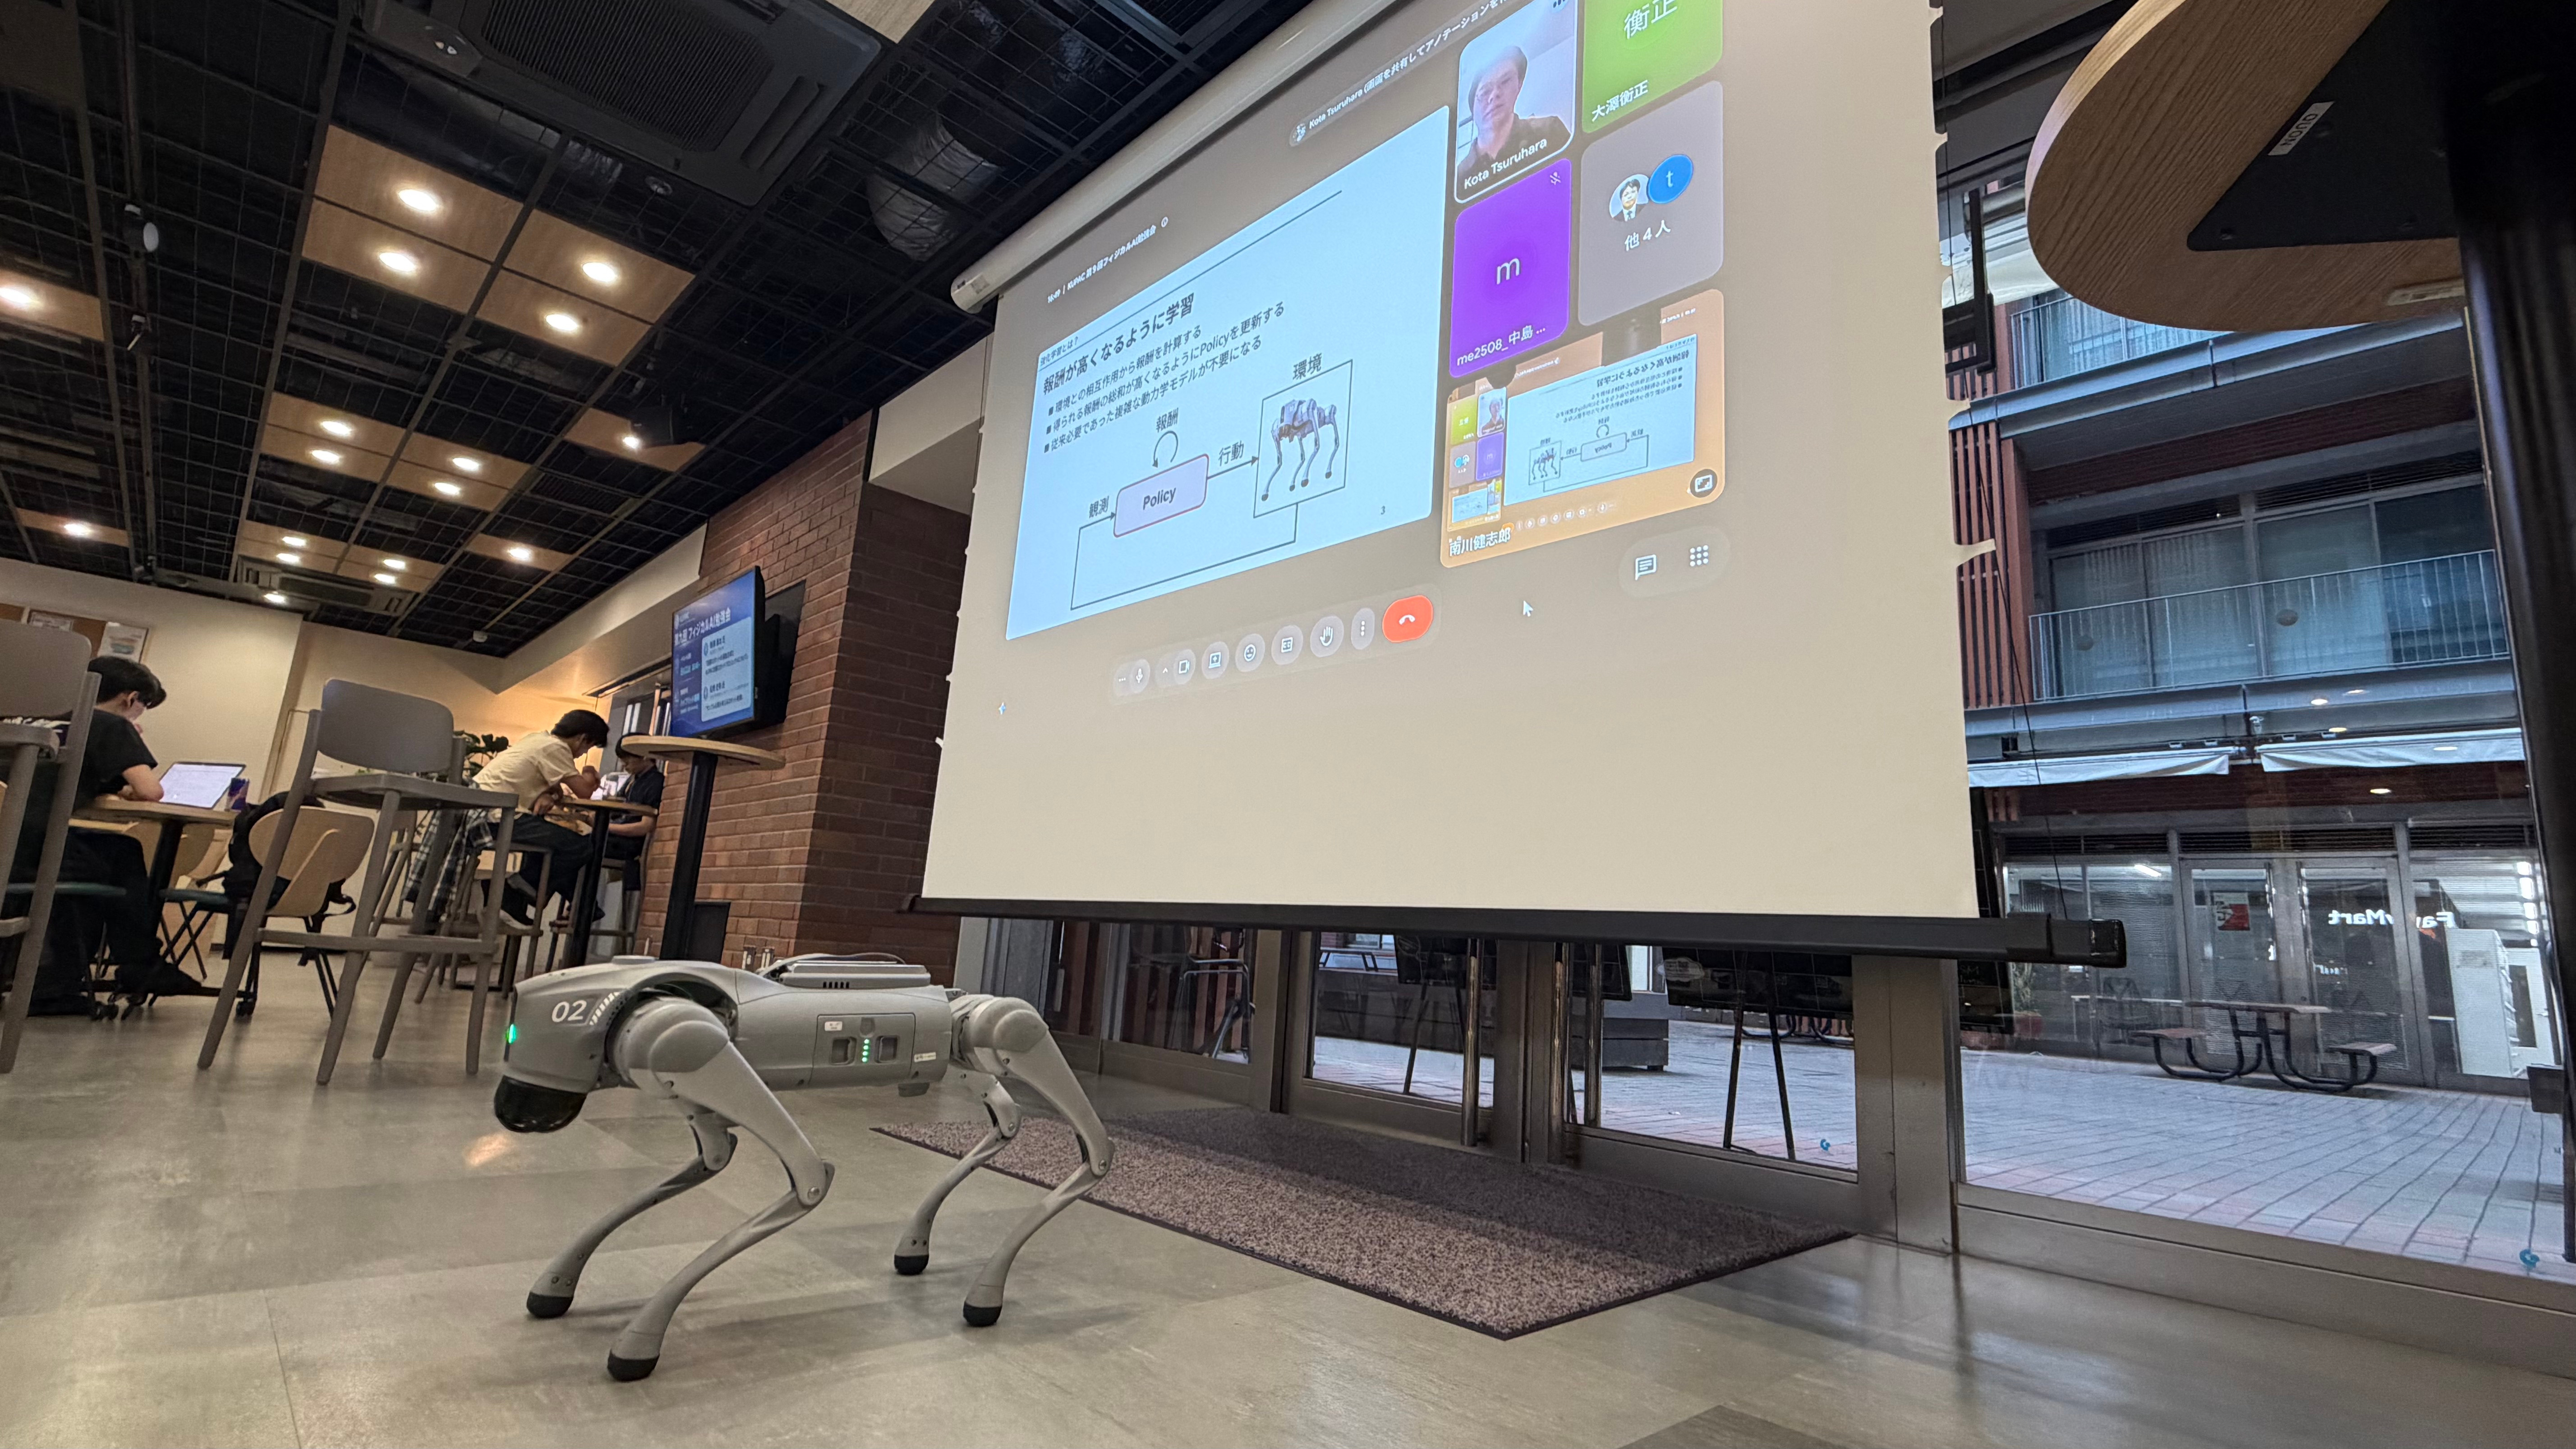
Presentation Scene (2)
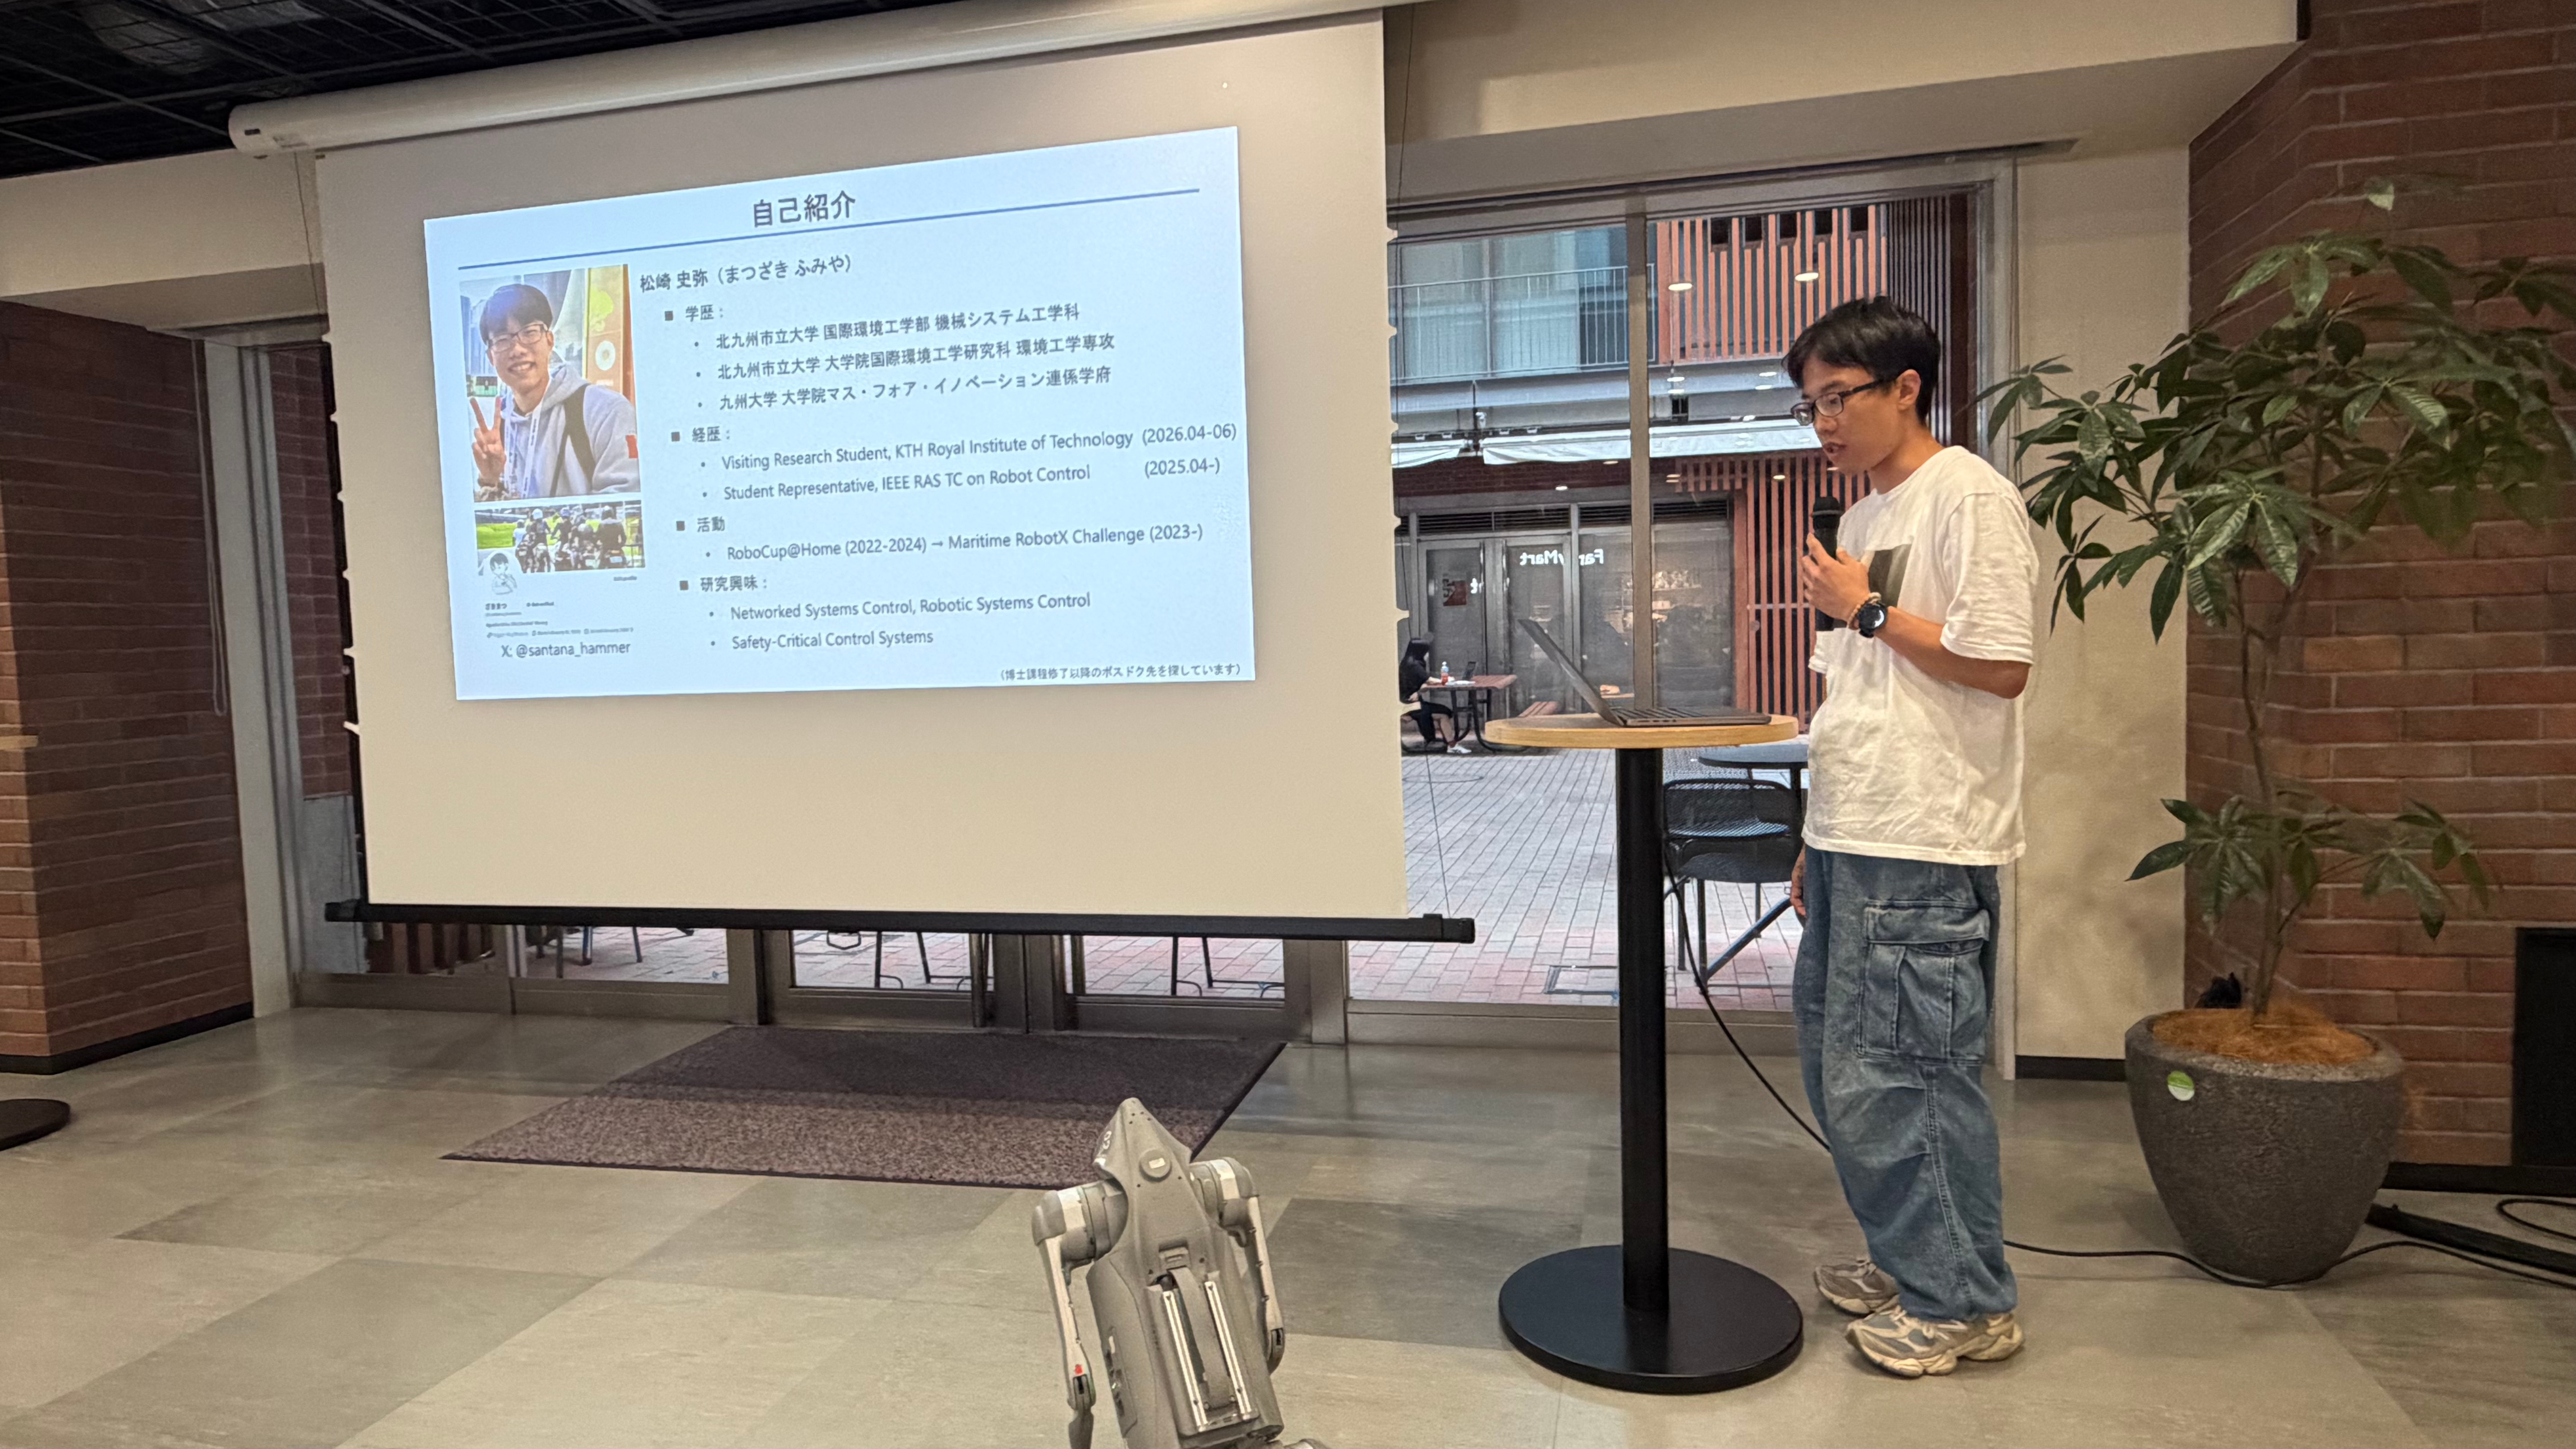
Presentation Scene (3)
* Click photo to enlarge